The accuracy of inertial navigation systems is significantly constrained by temperature effects. Under wide operating temperature ranges (e.g., -45°C to +70°C), the bias and scale factor of inertial components (gyroscopes and accelerometers) exhibit significant drift; errors associated with high-temperature drift and the low-temperature startup phase are particularly pronounced. High-temperature drift stems from changes in material properties as temperature rises, whereas low-temperature startup involves transient heat transfer effects during the establishment of the internal thermal field. To address these two critical issues, this paper systematically outlines optimization design methods from both hardware and algorithmic perspectives.
In high-temperature environments, drift in inertial components primarily arises from the temperature sensitivity of the materials. Taking silicon-based MEMS devices as an example, the relationship between the elastic modulus and temperature can be approximately expressed as: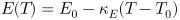 ;
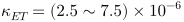
The temperature coefficient of the elastic modulus of silicon material. This change directly causes a shift in the resonant frequency: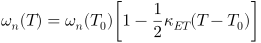
For a laser gyro, the relative error in the scale factor caused by the variation of the resonant cavity length with temperature is: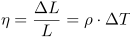
In the formula, ρ represents the coefficient of thermal expansion. Taking a glass-ceramic resonant cavity as an example, where ρ = 5.5 × 10⁻⁷/°C, a temperature change of 110°C introduces an error of approximately 60 ppm.
Thermal Control Architecture Design: A closed-loop thermal control system is established using a thermally insulated housing combined with a thermoelectric cooler (TEC) to maintain the operating zone of the inertial components at a near-constant temperature. Temperature sensors monitor the ambient temperature in real time, while the MCU regulates the direction and magnitude of the TEC current via a current controller, enabling dual-mode control for both heating and cooling.
Full-Temperature-Range Calibration and Hardware Compensation: A temperature compensation mechanism is incorporated into the analog-to-digital conversion stage. For high-precision I/F conversion circuits, a model correlating the circuit's intrinsic zero-offset output with the temperature field is established under zero-input-current conditions; subsequently, secondary compensation is applied to the acceleration channel as a whole to prevent mismatches between independent compensation efforts and the system's thermal environment.
Multivariate Temperature Field Modeling: A single thermometer cannot fully capture the complex temperature field distribution within the inertial navigation unit. The optimal approach utilizes data from the built-in thermometers of six inertial sensors to construct multidimensional temperature variables—specifically temperature ($T$), rate of temperature change ($\dot{T}$), and temperature gradient ($\nabla T$)—which serve as inputs for the compensation model.
Support Vector Regression (SVR) Modeling: Thermal drift in inertial components exhibits strong nonlinearity, rendering traditional polynomial fitting insufficiently accurate. SVR achieves nonlinear regression by mapping data into a high-dimensional feature space using kernel functions. The regression function is expressed as: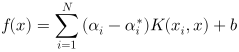
Select the radial basis kernel function: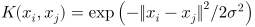
The kernel parameter σ and the penalty factor C significantly affect model accuracy, necessitating the use of meta-heuristic algorithms (such as the Gravitational Search Algorithm, GSA) for optimization. Experimental results demonstrate that the GSA-SVR-based compensation method can improve navigation accuracy by more than 50%.
Cold start represents one of the most rigorous challenges for inertial navigation products. Upon initial power-up, the system's internal temperature field has not yet stabilized; differences in thermal inertia among components lead to non-uniform transient temperature rises, causing drift errors to exhibit non-stationary characteristics. The key approach is to model the startup phase (typically the first 20 minutes) and the steady-state operation phase separately.
During a cold start, the resonant drive has not yet stabilized and the circuitry is in a warm-up state; temperature fluctuations stem primarily from heat generated by the components themselves. The magnitude of output drift during the gyroscope's startup phase is often several times greater than that observed during the steady-state phase. An initial error compensation value, $C(T_0)$, is obtained via a lookup table based on the temperature $T_0$ detected at the moment of startup to provide immediate compensation, which is then updated in real-time during subsequent operation.
An SVR (Support Vector Regression) scheme based on segmented modeling is employed: operational states are categorized based on the time elapsed since power-up (typically using a 900-second threshold), and separate temperature drift models are trained for the startup and steady-state phases. This strategy has been validated in fiber-optic gyro north-seeking instruments, where the accuracy during the startup phase improved from 0.0209° to 0.0101°, approaching the performance level of the steady-state phase.
The recursive form of the temperature error compensation can be expressed as follows: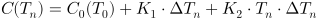
Here,
is the initial look-up table value at the start time,
is the temperature difference between consecutive sampling instants, and
are the error coefficients for the rate of temperature change and its quadratic term, respectively.
The issues of high-temperature drift and low-temperature startup in inertial navigation products are fundamentally manifestations of the interplay between material temperature sensitivity and thermal field non-uniformity. Engineering practice demonstrates that a synergistic strategy—using hardware thermal control to establish a baseline and algorithmic compensation to further enhance performance—is the most effective approach: at the hardware level, TEC-based thermal control and full-temperature-range calibration are employed to suppress the magnitude of drift, while at the algorithmic level, piecewise SVR multivariate modeling is used for refined residual compensation. Combining these methods effectively reduces startup time and improves accuracy across the entire operating temperature range of -45°C to +70°C.
leave a message
Scan to Wechat :