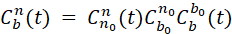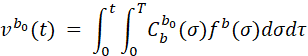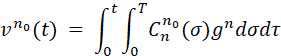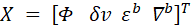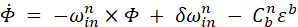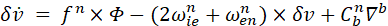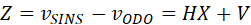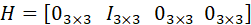
Performing initial alignment of a vehicle-mounted strapdown inertial navigation system (SINS) while in motion is a key technology for enhancing a vehicle's rapid maneuverability. The primary challenge lies in the fact that the interference accelerations introduced by the motion of the base are far greater than the useful signals—such as the Earth's angular velocity—rendering traditional analytical alignment methods ineffective. This paper outlines the fundamental principles of rapid alignment while in motion, with a focus on the mathematical mechanisms of "coarse alignment" via the inertial frame freezing method and "fine alignment" via Kalman filtering.
Under static base conditions, an inertial navigation system can determine its initial attitude matrix through direct analytical calculation, using the sensed gravity vector ($g$) and the Earth's angular velocity. However, when a vehicle is in motion, disturbances—arising from engine vibrations, road-induced excitations, and maneuvering accelerations—are several orders of magnitude larger than the Earth's rotation signal. Consequently, substituting raw measured values directly into analytical formulas leads to alignment failure.
Rapid alignment during motion typically employs a two-stage strategy: "coarse alignment" followed by "fine alignment." Coarse alignment utilizes the inertial frame freezing technique to quickly obtain an initial, rough estimate of the attitude matrix. Fine alignment then builds upon this, incorporating external auxiliary information (such as data from an odometer or GNSS) and employing a Kalman filter to estimate and compensate for misalignment angles and sensor errors.
The core concept of coarse alignment is to shift the computation of the attitude matrix into an inertial coordinate frame. This leverages the fact that the gravity vector rotates very slowly within inertial space, allowing for the isolation of disturbances caused by the vehicle's angular motion.
Basic formulation: By selecting a navigation inertial frame (n_0) and a body inertial frame (b_0) corresponding to the start time of the alignment process, the attitude matrix can be decomposed as follows:
Dual-vector construction: In the b_0 frame, perform a double integration of the specific force output from the accelerometer to construct a measurement vector:
In the n_0 frame, the gravity vector is known; construct a reference vector:
The attitude matrix obtained from coarse alignment has limited accuracy (with typical azimuth errors on the order of arcminutes). Fine alignment employs a Kalman filter to further reduce the error states.
State Equation: The state vector is defined to include the attitude misalignment angles Φ, velocity errors δv, gyroscope biases ε^b, and accelerometer biases ∇^b.
The attitude error equation is:
The velocity error equation is:
Measurement equation: Use the velocity provided by an odometer or GNSS as an external observation reference, and calculate the difference relative to the velocity derived from the inertial navigation system (INS) solution:
The measurement matrix for velocity matching is
Vehicle kinematic constraints can serve as virtual observations: ideally, the lateral and vertical velocities of the vehicle are zero—that is, vright≈0,vup≈0. Since these constraints do not rely on external sensors, they function as additional measurement information that enhances the observability of the alignment process.
Through iterative Kalman filtering, the misalignment angles and device biases gradually converge. The resulting estimates are then used to correct the attitude matrix and sensor outputs, thereby completing the fine-alignment process.
In summary, the essence of rapid alignment for a vehicle-mounted system on a moving base is twofold: first, a "coarse alignment" is performed using the inertial-frame-fixation method to isolate the system from the vehicle's motion; second, a Kalman filter is employed to fuse external velocity data, enabling the precise estimation and compensation of error states. The former addresses the challenge of determining attitude while in motion (effectively "finding stillness within motion"), while the latter addresses the challenge of improving accuracy by extracting signals from noise. Together, these processes allow an inertial navigation system (INS) to complete its alignment while the vehicle is in motion, enabling an immediate transition into the navigation state.
leave a message
Scan to Wechat :